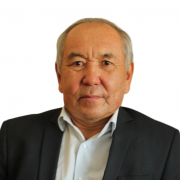
Beisembayev Akambay
Candidate of technical sciences
Assistant professor
Associate Professor
Institute of Automation and Information Technologies
Department of Automation and сontrol
Email: akambay.beisembayev@satbayev.111

Professional biography
After graduating from the institute in 1983, was distributed by an engineer at the Department of Automation and Telemechanics (ATM) of the Kazakh Polytechnic Institute (KazPTI) named after V.I. Lenin. In 1986, he was transferred to the post of senior engineer at the NICH Department of ATM.
In 1986 he entered the full-time graduate school of KazPTI named after V.I. Lenin. In 1989, he successfully completed full-time postgraduate studies and was distributed as an assistant at the ATM department. Further transferred to the post of teacher of the same department.
In 1991 he was transferred to the post of researcher, the newly organized Institute of Problems of Informatics and Management of the Academy of Sciences of the Kazakh SSR. Since 1993, a senior research fellow at the aforementioned institute.
In 1996 he moved to the Kazakh National Technical University (KazNTU) named after K.I. Satpayev, a senior lecturer at the Department of ATM. In 1997 he defended his thesis: "Development of models and algorithms for constructing robotic systems in non-ferrous metallurgy" for the degree of candidate of technical sciences.
From 1998 to 2000, deputy. Head of the Department of Automation and Radioelectronic Engineering of the Academy of the Ministry of Internal Affairs of the Republic of Kazakhstan.
In 2000, he was accepted as an assistant professor at the Department of ATMiRS KazNTU named after K.I. Satpayev. In 2004 he was awarded the academic title of Associate Professor. In 2003-2004 he worked as a deputy. Director of the Institute of Automation and Control Systems. In 2005-2006, deputy. Director of the Institute of Informatics and Information Technology. From 2008 to 2011, acting Director of the Institute of Automation and Telecommunications.
Since September 2011, an assistant professor of Automation and Control. From August 2016 to May 2017, associate professor of the Department of Automation and Management.
Education
In 1978 he entered in 1983, graduated from the Kazakh Polytechnic Institute named after V.I. Lenin, with the qualification of an electrical engineer in the specialty "Automation and Telemechanics"
From 1986 to 1989 he studied in full-time graduate school of the Kazakh Polytechnic Institute named after V.I. Lenin, at the department "Automation and Telemechanics"
In 1997 he defended his thesis on the topic: "Development of models and algorithms for constructing robotic systems of one class of technological processes", specialty 051301 - Management in technical systems.
In 2005, she was awarded the academic title of Associate Professor in the field of Computer Science, Computer Engineering and Management.
Scientific projects
Development and research of models and algorithms for software control of manipulation robots using R - functions.
Using the mathematical apparatus of R - functions, the working spaces of the manipulation robot are described. Based on the description obtained, algorithms are developed for solving the inverse kinematics problem. Based on the obtained values of the generalized coordinates, software trajectories are developed for each degree of robot mobility. Further, taking into account the values of velocities and accelerations in terms of the degrees of mobility of the robot, program trajectories are coordinated. The obtained values of the generalized coordinates with respect to the degrees of mobility of the robot are approximated by Lagrange polynomials. Determining the derivatives of the obtained polynomials, laws of change of speeds are developed according to the degrees of mobility of the robot. Thus, software trajectories of manipulation robot control are developed.
These studies are carried out in joint studies with doctoral candidate A. Erbosynova, F. Tairova.
Publications
1. Байбатшаев М.Ш., Бейсембаев А.А., Балгабаев М.А., Ибрагимов Р.И. Выбор промышленных роботов по рабочим зонам. Вопросы создания АСУ технологическими процесс-сами и предприятиями. - Алма-Ата, КазПТИ, 1985, с. 158-167.
2. Байбатшаев М.Ш., Бейсембаев А.А., Коломийцев А.В., Конысбеков М.К., Рыжов В.Г. Устройство для переброса струи металла в изложницы на литейном конвейере. Авторское свидетельство СССР. №1404172, B22D35/00, 22.08.88.
3. Байбатшаев М.Ш., Исембергенов Н.Т., Курмашев Н.М., Бейсембаев А.А. Манипулятор для переброса струи металла в изложницы на литейном конвейере. Механизация и автоматизация производства. №6, М.: Машиностроение, 1988, с.7-8.
4. Байбатшаев М.Ш., Бейсембаев А.А., Курмашев Н.М. РТК для разливки жидкого магния. Механизация и автоматизация производства. №12, М.: Машиностроение, 1988, с.4-5.
5. Сыздыков Д.Ж., Байбатшаев М.Ш., Бейсембаев А.А. Синтез программных траекторий манипуляционного робота на основе описания рабочих зон с применением R-функций. Моделирование и управление в гибких автоматизированных производствах и системах автоматического управления. Межвуз. Сб. науч. тр. МИРЭА. – М.: 1990. с. 20-29.
6. Байбатшаев М.Ш., Бейсембаев А.А. Устройство для переброса металла в изложницы на литейных конвейерах. А.с. патента Республики Казахстан №1169, 1992. - 5с.
7. Baybatshaev M., Dusembaev A., Beysembaev A. Modelling the robotic systems by methods of discrete analysis for special class of production processes. 3-rd International Workshop on advanced motion control. USA, California, Bercley. 20-23 march. 1994, p.41-48.
8. Байбатшаев М.Ш., Бейсембаев А.А. Формализованное описание робото-автоматизированной системы одного класса технологических процессов. Вестник КазНТУ, №2, 1995, с. 59-62.
9. Бейсембаев А.А. Алгоритм программного управления манипуляционным роботом в пространстве координат схвата. Вестник КазНТУ им. К.И. Сатпаева, 2002 г. № 2 (30) Алматы, 2002. – с.161-167.
10. Бейсембаев А.А. Синтез программ-много управления манипуляционным роботом в рабочем пространстве манипуляционного робота. Вестник КазНТУ им. К.И. Сатпаева, 2002 г. № 2 (30) Алматы, 2002. – с.151-161.
11. Байгунчеков Ж.Ж., Байбатшаев М.Ш., Бейсембаев А.А. Синтез программных траекторий с учетом препятствий в рабочем пространстве манипуляционного робота. Сибирское отделение РАН, КазНУ им. Аль-Фараби/Вычислительные технологии, т.7., Вестник КазНУ им. Аль-Фараби, сер. Математика, механика, информатика, №5. 2002. – с. 29-34.
12. Байбатшаев М.Ш., Бейсембаев А.А. Метод построения роботоавтоматных систем. Вестник КазНТУ им. К.И. Сатпаева, 2008 г. №6(1) Алматы, 2008. с.52-58.
13. Бейсембаев А.А. Синтез программных траекторий по степеням подвижности манипуляционного робота. Вестник КазНТУ им. К.И. Сатпаева, 2008 г. №6(1) Алматы, 2008. с.69-73.
14. Бейсембаев А.А. Описание рабочих пространств манипуляционного робота, имеющего три степени подвижности в виде логических выражений. Известия Национальной академии наук Республики Казахстан. Серия физико-математическая. №5 (273) Алматы, НАН РК, 2010. с. 80-87.
15. Бейсембаев А.А., Бүрлібай А. Декомпозиция процесса производства товарного магния на элементарные подпроцессы. Вестник Национальной академии наук Республики Казахстан. №6 Алматы, 2010. с. 71-74.
16. Бейсембаев А.А., Акышева Г.К., Омирбекова Ж.Ж., Бүрлибай А.Ә. Устройство для измерения температуры движущихся изложниц литейного конвейера производства товарного магния. Вестник КазНТУ им. К.И. Сатпаева, №2(90) Алматы, 2012. с.216-220.
17. Бейсембаев А.А., Бүрлібай А.Ә., Омирбекова Ж.Ж. Прибор для удаления шлака или аналогичных отходов с поверхности расплавленного металла. Вестник КазНТУ им. К.И. Сатпаева, №1(89) Алматы, 2012. с.202-206.
18. Beisembaev A., Burlibay A. Programm trajectories of robot manipulator by using of Lagrang interpolation polynomials. Вестник КазНТУ им. К.И. Сатпаева, №6(94) Алматы, 2012. С.72-76.
19. Байбатшаев М.Ш., Бейсембаев А.А., Куанбаев А. Метод построения роботоавтоматных систем. Поиск №2 2014. с. 317-323.
20. Бейсембаев А.А., Ербосынова М.С., Әсембай А.Ә. Алгоритм программного управления, устройством для измерения температуры движущихся изложниц, литейного конвейера производства товарного магния. Поиск. №4, 2014. с. 43-49.
21. Бейсембаев А.А., Әсембай А. Стратифицированное описание литейного производства товарного магния. Вестник КазНИТУ. №3(121) 2017. с. 183-190.
22. Бейсембаев А.А., Әсембай А. Формализованное описание и алгоритм построения компоновочной схемы роботизированного технологического комплекса. Вестник КазНИТУ. №3(121) 2017. с. 557-563.
23. Байбатшаев М.Ш., Сулейменов Б.А., Бейсембаев А.А. Устройство для разлива жидкого магния на литейном конвейере. Патент № 34185. Бюл. №8. 28.02.2020, 8 с.
24. Aron Abiluly Burlibay, Akambay Agybayuly Beisembaev, Waldemar Wyjcik. Description of the manipulator robot’s workspaces with three mobility degrees in the form of the logical expressions. PREZGLAD ELEKTROTECHNICZNY, ISSN 0033-2097, R. 90 NR 8/2014. p. 25 – 29. DOI:10.12915/pe.2014.08.06
25. Beisembayev Akambay, Yerbossynova Anargul, Pavlenko Petro, Baibatshayev Mukhit. Method for analytical description and modeling of the working space of a manipulation robot. Eastern European Journal of Enterprise Technologies. Том 6, Выпуск 7(114), 2021. 12 – 20 с. ISSN 1729-3774. https://doi.org/10.15587/1729-4061.2021.246533. (Scopus) Engineering – 38% процентиль.
26. Akambay Beisembayev, Anargul Yerbossynova, Petro Pavlenko, Mukhit Baibatshayev. Planning trajectories of a manipulation robot with a spherical coordinate system for removing oxide film in the production of commercial lead, zinc. Eastern-European Journal of Enterprise Technologies Vol 4, No 2, (124) August 2023, Information technology. Industry control systems. p. 80-89. ISSN 1729-3774. https://doi.org/10.15587/1729-4061.2023.286463. (Scopus), (2022), Engineering – 40% процентиль.
27. Akambay Beisembayev, Anargul Yerbossynova, Petro Pavlenko, Mukhit Baibatshayev. Development of programmed trajectories based on the mobility degrees of manipulation robot with a spherical coordinate system for removing oxide film in the production of commercial magnesium. Eastern-European Journal of Enterprise Technologies. Vol. 1 No. 1 (127) (2024), Information technology. Industry control systems. p. 67-88. ISSN 1729-3774. https://doi.org/10.15587/1729-4061.2024.298912. (Scopus), (2022), Engineering – 40% процентиль.
| № | Article title | Journal title | Direction | Year |
|---|---|---|---|---|
| 1 | Разработка программных траекторий манипуляционного робота для снятия оксидной пленки при производстве товарного магния. | «М.Тынышбаев атындағы Қазақ көлік және коммуникациялар академиясының Хабаршысы» ғылыми журналы | Көлік, көлік инженериясы, көлік логистикасы, жүк тасуды ұйымдастыру, автоматтандыру, телемеханика, байланыс, энергетика | 2023 |
| 2 | Разработка программных траекторий манипуляционного робота для снятия оксидной пленки при производстве товарного свинца, цинка. | «М.Тынышбаев атындағы Қазақ көлік және коммуникациялар академиясының Хабаршысы» ғылыми журналы | Көлік, көлік инженериясы, көлік логистикасы, жүк тасуды ұйымдастыру, автоматтандыру, телемеханика, байланыс, энергетика | 2023 |
| 3 | Бейсембаев А.А., Ербосынова А.С., Таирова Ф.Л., Бақтыбай А.А. Аналитическое описание рабочих пространств манипуляционных роботов, работающих в цилиндрической системе координат в виде логических функций. | М. Тынышбаев атындағы Қазақ көлік және коммуникациялар академиясының хабаршысы | Ақпараттық-коммуникациялық технологиялар | 2026 |
| 4 | Бейсембаев А.А., Таирова Ф.Л., Ербосынова А.С., Ниеткалиев Б.А. Роботизированная технологическая ячейка перевода потока магниевого расплава между движущимися изложницами литейного конвейера. | М. Тынышбаев атындағы Қазақ көлік және коммуникациялар академиясының хабаршысы | Ақпараттық-коммуникациялық технологиялар | 2026 |
| 5 | Бейсембаев А.А., Таирова Ф.Л., Ербосынова А.С., Сарсенбаев Н.С., Искакова А.М. Роботизация технологической операции снятия оксидной пленки при производстве товарного магния. | М. Тынышбаев атындағы Қазақ көлік және коммуникациялар академиясының хабаршысы | Ақпараттық-коммуникациялық технологиялар | 2026 |
Potential research studies of doctoral students
Robotization of non-ferrous metallurgy production processes. Research and development work related to the robotization of transferring a stream of metal between the joints of molds, removing the oxide film from the surface of lead, zinc and magnesium poured into molds.
Development of algorithms for selecting a model of an industrial robot in the robotization of production processes. Research work on the development of algorithms for selecting models of industrial robots for workspaces, using logical functions.
Development of models and algorithms for constructing layout diagrams of robotic technological complexes. Research work on the development of algorithms for constructing layout diagrams, when approximating elements of robotic systems, rectangular cylinders, rectangular prisms.
Development of models and algorithms for the synthesis of programmed trajectories of manipulation robots. Research work on the use of logical functions for solving the problem of synthesizing program trajectories.
Development of models and algorithms for describing the workspaces of manipulation robots using logical functions.